|
[1]
|
A. A. Agrachev and Y. L. Sachkov, Control Theory from the Geometric Viewpoint, Encyclopaedia Math. Sci., 87. Control Theory Optim., Ⅱ. Springer-Verlag, Berlin, 2004.


|
|
[2]
|
A. A. Agrachev and A. Sarychev, Control on the manifolds of mappings with a view to the deep learning, J. Dyn. Control Syst., 28 (2022), 989-1008.
doi: 10.1007/s10883-021-09561-2.
|
|
[3]
|
S. Arguillère, E. Trélat, A. Trouvé and L. Younes, Shape deformation analysis from the optimal control viewpoint, J. Math. Pures. Appl., 104 (2015), 139-178.
doi: 10.1016/j.matpur.2015.02.004.
|
|
[4]
|
S. Arguillère, E. Trélat, A. Trouvé and L. Younes, Registration of multiple shapes using constrained optimal control, SIAM J. Imaging Sci., 9 (2016), 344-385.
doi: 10.1137/15M1006726.
|
|
[5]
|
K. Beauchard, J. Le Borgne and F. Marbach, On expansions for nonlinear systems error estimates and convergence issues, C. R. Math., 361 (2023), 97-189.
doi: 10.5802/crmath.395.
|
|
[6]
|
M. F. Beg, M. I. Miller, A. Trouvé and L. Younes, Computing large deformation metric mappings via geodesic flows of diffeomorphisms, Int. J. Comput. Vis., 61 (2005), 139-157.
doi: 10.1023/B:VISI.0000043755.93987.aa.
|
|
[7]
|
B. Ben Amor, S. Arguillere and L. Shao, ResNet-LDDMM: Advancing the LDDMMframework using deep residual networks, IEEE Trans. Pattern Anal. Mach. Intell., 45 (2023), 3707-3720.
doi: 10.1109/TPAMI.2022.3174908.
|
|
[8]
|
C. M. Bishop, Pattern Recognition and Machine Learning, Inf. Sci. Stat., Springer, New York, 2006.
|
|
[9]
|
A. Bistoquet, J. Oshinski and O. Skrinjar, Myocardial deformation recovery from cine MRI using a nearly incompressible biventricular model, Med. Image Anal., 12 (2008), 69-85.
doi: 10.1016/j.media.2007.10.009.
|
|
[10]
|
A. Bloch, P. S. Krishnaprasad, J. E. Marsden and T. S. Ratiu, The Euler–Poincaré equations and double bracket dissipation, Commun. Math. Phys., 175 (1996), 1-42.
doi: 10.1007/BF02101622.
|
|
[11]
|
M. Bruveris, Geometry of Diffeomorphism Groups and Shape Matching, Ph.D. thesis, Imperial College London, 2012.
|
|
[12]
|
M. Bruveris and D. D. Holm, Geometry of image registration: The diffeomorphism group and momentum maps, Geometry, Mechanics, and Dynamics, Fields Inst. Commun., Springer, New York, 73 (2015), 19-56.
doi: 10.1007/978-1-4939-2441-7_2.
|
|
[13]
|
E. Celledoni, M. J. Ehrhardt, R. I. Etmann, Ca nd McLachlan, B. Owren, C.-B. Schönlieb and F. Sherry, Structure-preserving deep learning, Eur. J. Appl. Math., 32 (2021), 888-936.
doi: 10.1017/S0956792521000139.
|
|
[14]
|
E. Celledoni, H. Glöckner, J. N. Riseth and A. Schmeding, Deep neural networks on diffeomorphism groups for optimal shape reparametrization, BIT Numer. Math., 63 (2023), Paper No. 50, 38 pp.
doi: 10.1007/s10543-023-00989-5.
|
|
[15]
|
C. Ceritoglu, X. Tang, M. Chow, D. Hadjiabadi, D. Shah, T. Brown, M. Burhanullah, H. Trinh, J. Hsu, K. Ament, D. Crocetti, S. Mori, S. Mostofsky, S. Yantis, M. I. Miller and T. J. Ratnanather, Computational analysis of LDDMM for brain mapping, Front. Neurosci., 7 (2013), 151.
doi: 10.3389/fnins.2013.00151.
|
|
[16]
|
A. Cifor, L. Risser, D. Chung, E. M. Anderson and J. A. Schnabel, Hybrid feature-based diffeomorphic registration for tumor tracking in 2-D liver ultrasound images, IEEE Trans. Med. Imaging, 32 (2013), 1647-1656.
doi: 10.1109/TMI.2013.2262055.
|
|
[17]
|
N. Ganaba, Deep learning: Hydrodynamics, and Lie-Poisson Hamilton-Jacobi theory, arXiv: 2105.09542v2, (2021).
|
|
[18]
|
J. A. Glaunes, Transport par Difféomorphismes de Points, Demesures et de Courants Pour la Comparaisonde Formes et L'Anatomie Numérique, Ph.D. thesis, Université Paris 13, 2005.
|
|
[19]
|
U. Grenander, General Pattern Theory, Clarendon Press, Oxford, 1993.
|
|
[20]
|
B. Gris, S. Durrleman and A. Trouvé, A Sub-Riemannian modular framework for diffeomorphism-based analysis of shape ensembles, SIAM J. Imaging Sci., 11 (2018), 802-833.
doi: 10.1137/16M1076733.
|
|
[21]
|
R. S. Hamilton, The inverse function theorem of Nash and Moser, Bull. Am. Math. Soc., 7 (1982), 65-222.
doi: 10.1090/S0273-0979-1982-15004-2.
|
|
[22]
|
K. He, X. Zhang, S. Ren and J. Sun, Deep residual learning for image recognition, 2016 IEEE Conference on Computer Vision and Pattern Recognition (CVPR), (2016), 770-778.
|
|
[23]
|
L. Hörmander, Hypoelliptic second order differential equations, Acta Math., 119 (1967), 147-171.
doi: 10.1007/BF02392081.
|
|
[24]
|
T. Hytönen, J. van Neerven, M. Veraar and L. Weis, Analysis in Banach Spaces: Volume Ⅰ: Martingales and Littlewood-Paley Theory, Springer, 2016.
|
|
[25]
|
S. C. Joshi and M. I. Miller, Landmark matching via large deformation diffeomorphisms, IEEE Trans. Image Process., 9 (2000), 1357-1370.
doi: 10.1109/83.855431.
|
|
[26]
|
V. Jurdjevic, Optimal control, geometry, and mechanics, Mathematical Control Theory, (1999), 227-267.
doi: 10.1007/978-1-4612-1416-8_7.
|
|
[27]
|
Y. LeCun, A theoretical framework for back-propagation, D. Touretzky, G. Hinton and T. Sejnowski, Proceedings of the 1988 connectionist models summer school, Morgan Kaufmann, CMU, Pittsburgh, Pa, (1988), 21-28.
|
|
[28]
|
Q. Li, L. Chen, T. Cheng and E. Weinan, Maximum principle based algorithms for deep learning, J. Mach. Learn. Res., 18 (2017), 5998-6026.
|
|
[29]
|
T. Mansi, X. Pennec, M. Sermesant, H. Delingette and N. Ayache, iLogDemons: A demons-based registration algorithm for tracking incompressible elastic biological tissues, Int. J. Comput. Vis., 92 (2010), 92-111.
doi: 10.1007/s11263-010-0405-z.
|
|
[30]
|
J. E. Marsden and T. Ratiu, Introduction to Mechanics and Symmetry, Springer, 1999.
|
|
[31]
|
W. Miller, Computational complexity and numerical stability, Proceedings of the Sixth Annual ACM Symposium on Theory of Computing, Association for Computing Machinery, (1974), 317–322.
|
|
[32]
|
P. K. Mogensen and A. N. Riseth, Optim: A mathematical optimization package for Julia, J. Open Source Softw., 3 (2018), 615.
doi: 10.21105/joss.00615.
|
|
[33]
|
J. Nielsen Clelland, C. Moseley and G. R. Wilkens, Geometry of control-affine systems, Symmetry Integr. Geom., 5 (2009), Paper 095, 28 pp.
|
|
[34]
|
H. Owhadi, Do ideas have shape? Idea registration as the continuous limit of artificial neural networks, Physica D, 444 (2023), 133592, 41 pp.
doi: 10.1016/j.physd.2022.133592.
|
|
[35]
|
O. Öktem, C. Chong, D. Nevzat, R. Pradeep and B. Chandrajit, Shape based image reconstruction using linearized deformations, Inverse Probl., 33 (2017), 035004, 33 pp.
doi: 10.1088/1361-6420/aa55af.
|
|
[36]
|
A. Paszke, S. Gross, F. Massa, A. Lerer, J. Bradbury, G. Chanan, T. Killeen, Z. Lin, N. Gimelshein, L. Antiga, A. Desmaison, A. Kopf, E. Yang, Z. DeVito, M. Raison, A. Tejani, S. Chilamkurthy, B. Steiner, L. Fang, J. Bai and S. Chintala, PyTorch: An imperative style, high-performance deep learning library, Advances in Neural Information Processing Systems 32, (2019), 8024-8035.
|
|
[37]
|
C. Rackauckas and Q. Nie, Differentialequations.jl–A performant and feature-rich ecosystem for solving differential equations in Julia, J. Open Res. Softw., 5 (2017).
doi: 10.5334/jors.151.
|
|
[38]
|
J. Revels, M. Lubin and T. Papamarkou, Forward-mode automatic differentiation in Julia, CoRR, (2016).
|
|
[39]
|
L. Risser, F. X. Vialard, H. Y. Baluwala and J. A. Schnabel, Piecewise-diffeomorphic image registration: Application to the motion estimation between 3D CT lung images with sliding conditions, Med. Image Anal., 17 (2013), 182-193.
doi: 10.1016/j.media.2012.10.001.
|
|
[40]
|
A. Scagliotti, Deep learning approximation of diffeomorphisms via linear-control systems, Math. Control. Relat. Fields, 13 (2023), 1226-1257.
doi: 10.3934/mcrf.2022036.
|
|
[41]
|
H. J. Sussmann, A product expansion for the Chen series, Theory and Applications of Nonlinear Control Systems, (1986), 323-335.
|
|
[42]
|
P. Tabuada and B. Gharesifard, Universal approximation power of deep residual neural networks via nonlinear control theory, ICLR, (2021).
|
|
[43]
|
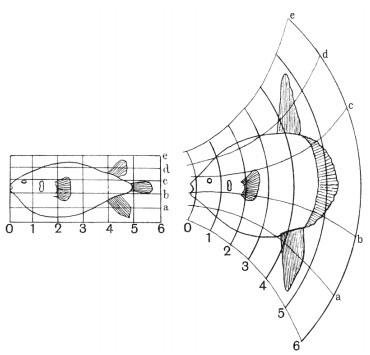
D. Thompson, On Growth and Form, Cambridge University Press, 1917.
|
|
[44]
|
F. Vialard, R. Kwitt, S. Wei and M. Niethammer, A shooting formulation of deep learning, Advances in Neural Information Processing Systems, 33 (2020), 11828-11838.
|
|
[45]
|
F.-X. Vialard, L. Risser, D. Rueckert and C. J. Cotter, Diffeomorphic 3D image registration via geodesic shooting using an efficient adjoint calculation, Int. J. Comput. Vis., 97 (2011), 229-241.
doi: 10.1007/s11263-011-0481-8.
|
|
[46]
|
L. Younes, Shapes and Diffeomorphisms, Appl. Math. Sci., 171. Springer, 2010.
|
|
[47]
|
L. Younes, Diffeomorphic learning, J. Mach. Learn. Res., 21 (2020), Paper No. 220, 28 pp.
|
|
[48]
|
L. Younes, B. Gris and A. Trouvé, Sub-riemannian methods in shape analysis, Handbook of Variational Methods for Nonlinear Geometric Data, (2020), 463-495.
doi: 10.1007/978-3-030-31351-7_17.
|


 Download:
 {{journal.titleEn}}

